nexuni odoseries

Autonomous Inspection Quadruped

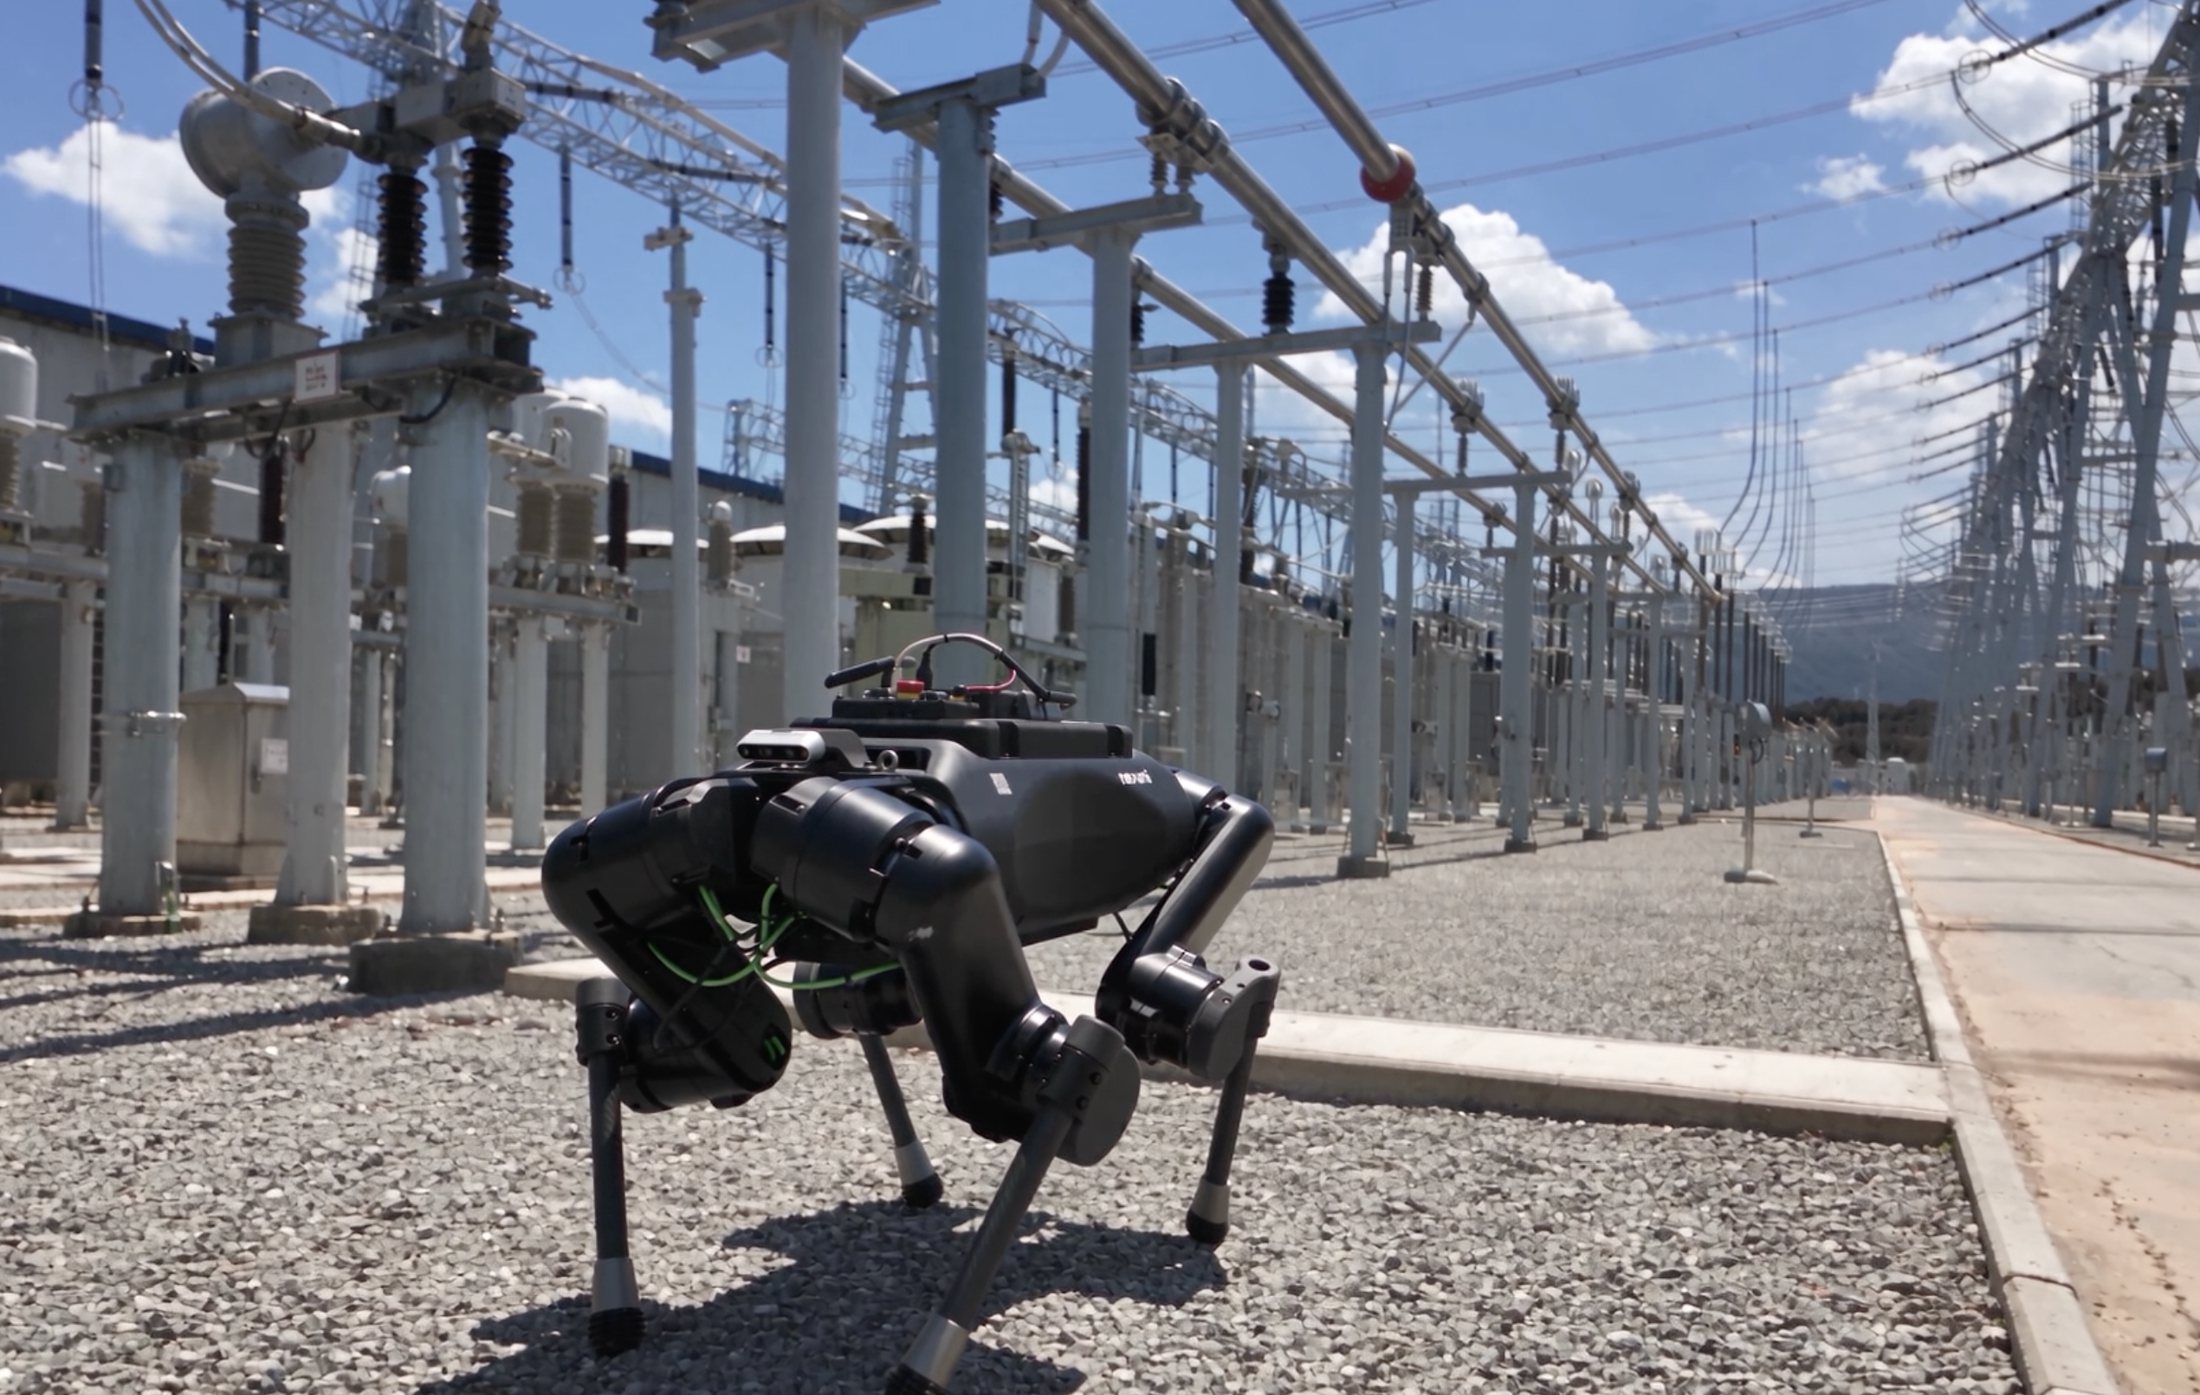
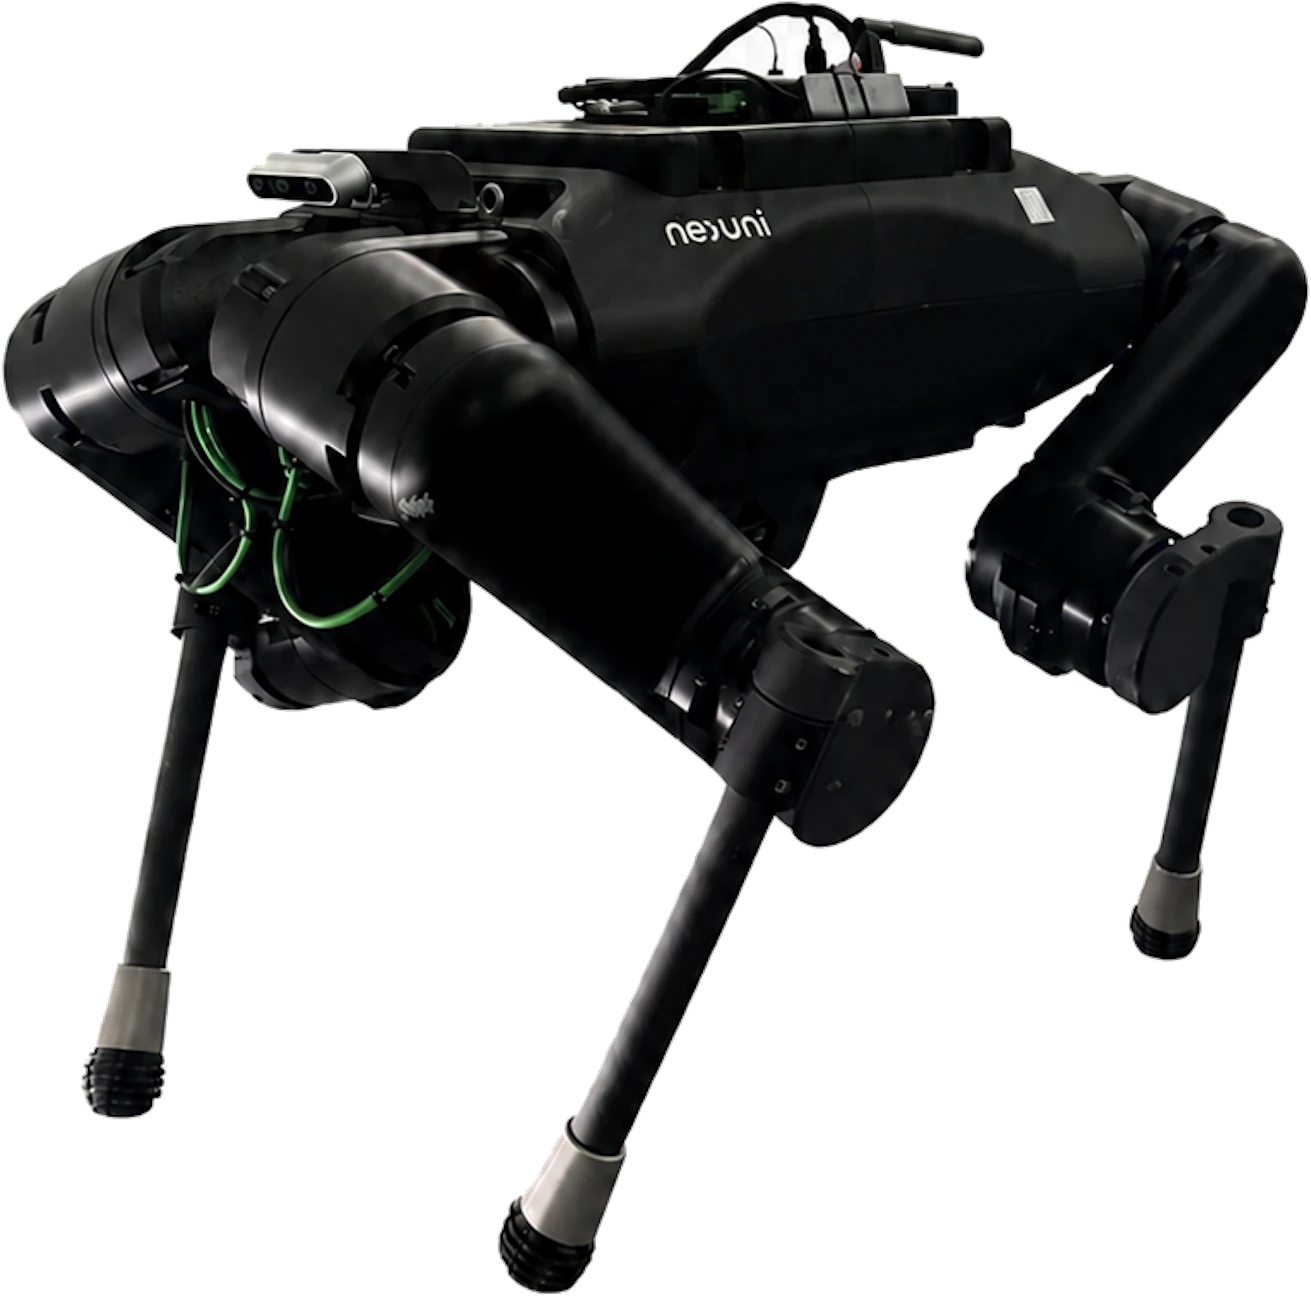
Three models share one NIRO brain for patrol, inspection and on-site records. The flagship odo 9 runs on a fully Nexuni-made quadruped platform.

Current Industry Challenges

  • Large sites and long shifts make patrol and inspection staff hard to hire and keep, with nights and holidays the hardest to cover.
  • Gauges, valves and equipment temperatures are logged by hand on a schedule, so readings get missed or misread and faults surface late.
  • High-voltage, high-temperature, gas-leak and confined areas put people at risk just by entering.
  • Fixed cameras and sensors leave blind spots and cannot walk over to check an anomaly.
  • Records are mostly paper or verbal, without timestamps or images, so rounds are hard to trace and audit.

Our Product

The Nexuni Autonomous Inspection Quadruped (odo series) patrols the whole plant on a schedule or on an event, reading gauges, capturing thermal images and detecting gas and abnormal sounds, on stairs, slopes and outdoor ground alike.

Every checkpoint leaves a timestamped image and reading. Anomalies are pushed to the management platform in real time and a robot can be sent to confirm them, so nobody has to enter a high-risk area and no station gets skipped.

Scheduled rounds

Fixed routes and checkpoints, day and night, with auto-recharge.

Event-driven response

When an intruder is spotted, an alarm goes off or the CCTV raises an alert, the robot heads to the spot, checks it and reports back.

Inspection & readings

Gauges, thermal, leaks and gas, judged on board with an evidence photo per stop.

Fully automated patrol and inspection.

Routine rounds run on a schedule. When an anomaly is detected or a command comes in, the robot switches tasks immediately and heads to the area to check the scene, cutting incident response time.

Patrols 24/7, day and night.

odo series robots follow the scheduled route, give way to pedestrians and finish the round in the dark, with no one driving.

  • Scheduled or on-demand routes with checkpoints; back to the dock to recharge between rounds
  • Slows, gives way and re-plans around pedestrians and obstacles

Supervise the whole fleet from one screen.

NIRO's fleet console puts every robot's live cameras, map position, task history and event log in front of one operator, who can take manual control at any moment.

  • Event logEvery detection with time, type and robot; alerts forwarded to your VMS, BMS and access control.
  • Task historyEvery mission with its outcome and the evidence photo from each checkpoint.
  • Live mapSLAM map with each robot's position and route; one operator supervises the whole fleet.

Every checkpoint leaves evidence.

At each stop an odo series robot takes a time-stamped photo, judges it on board and files a verdict with a confidence score, so a round is a record, not a verbal report.

  • Time-stamped photo: taken at the checkpoint, from the angle the route defines, on every round
  • Verdict and confidence: normal or abnormal, judged on the robot, with a confidence score and the reason
  • Exportable and auditable: reports go to your systems through the API or as files; the full audit log stays on site
CHECKPOINT RECORD · ONE PER STOP
STOP
checkpoint number and label from your route
TIME
on-board clock, start and end of dwell
PHOTO
one frame per stop, PTZ or thermal
VERDICT
PASSATTENTIONFAILwith confidence
ACTION
webhook, ticket, or human review

Full multi-floor coverage: stairs, steep slopes and elevators.

A high-mobility design takes stairs, steep slopes and uneven ground, and works with the elevator system to patrol across floors, turning inspection from single-point monitoring into full-area coverage.

nexuni odo 1 climbing outdoor granite steps

Stairs, steps, slopes, elevators

  • Legged odo 9: stairs, 20 cm steps and 30° slopes
  • Elevators and doors through BMS and access-control integration

Autonomous exploration, no map needed

  • Picks its next exploration target by itself and maps as it moves
  • For search after an earthquake, lanes no vehicle can enter, and smoke-filled interiors before firefighters go in

A quadruped trained with AI.

The difference is how it is trained, and the brain that makes it actually work.

Trained in simulation

  • Digital twin of your site in Isaac Sim / Isaac Lab
  • RL locomotion and navigation: flat ground, rough terrain, stairs, slopes
  • Trained in the simulator, deployed straight to the robot

Powered by NIRO

  • One instruction → route plan → execution → exception handling
  • 100% local inference on NVIDIA Jetson; footage stays on site
  • Perception and control API; integrates with your existing CCTV

Fast to deploy, highly scalable, and integrates with your existing systems.

Site & hardware

  • Charging dock on the route; the robot returns by itself
  • One 110–220 V outlet at the dock
  • Hard, flat floor; steps up to 20 cm (15 cm on odo 1)

Software & integration

  • Dashboard on the site network; the round itself runs offline
  • Open API and webhooks into your security or MES platform
  • Optional VMS / CCTV integration

Data & security

  • All inference runs on the robot; no cloud dependency
  • Footage and reports stay inside the site
  • Role-based access and a full audit log of every round

Why the name odo

odo comes from odometry, the robotics term for knowing where you are and where you are going. It is also all + do: not just seeing or analysing, but going in and getting the job done.

Three models. Pick the one your site needs.

nexuni odo 9 black legged flagship quadruped with a white sensor backpack

Flagship: industrial-grade indoor and outdoor inspection on a fully Nexuni-made quadruped platform, IP67 water and dust protection.

ModelNXBOT-ODO9
Dimensions L × W × H862 × 595 × 698 mm
Weight52.9 kg
Max walking speed1.2 m/s
Battery runtime2.5–3 h
Ingress ratingIP67
Max step height20 cm
Max slope30°
ComputeNVIDIA Jetson Thor

Specifications shown are odo 9 design values; final production specifications may vary.

nexuni odo 3 silver wheeled-leg quadruped with a sensor backpack

Advanced model: industrial-grade all-weather indoor and outdoor inspection.

Model
NXBOT-ODO3
Environment
Indoor & outdoor, all weather
Ingress rating
IP56
Runtime
2.5–3 h · auto-recharge
Step / slope
20 cm · 30°
nexuni odo 1 grey wheeled-leg entry model with a black nexuni sensor head

Entry model: for indoor patrol and fair-weather outdoor patrol.

Model
NXBOT-ODO1
Environment
Indoor & fair-weather outdoor
Ingress rating
IP54
Runtime
1.5–2 h · auto-recharge
Step / slope
15 cm · 20°
Specification comparison of odo 1, odo 3 and odo 9
Specificationodo 1odo 3odo 9
ModelNXBOT-ODO1NXBOT-ODO3NXBOT-ODO9
RoleEntryAdvancedFlagship
LocomotionWheeled-legWheeled-legLegged
PlatformCOTS quadruped platformCOTS quadruped platformFully Nexuni-made
EnvironmentIndoor & fair-weather outdoorIndoor & outdoor, all weatherIndoor & outdoor, all weather
Ingress ratingIP54IP56IP67
Dimensions70 × 43 × 60 cm90 × 44 × 73 cm86.2 × 59.5 × 69.8 cm
Weight≈ 15 kg≈ 37 kg52.9 kg
Runtime1.5–2 h · auto-recharge2.5–3 h · auto-recharge2.5–3 h · auto-recharge
Step / slope15 cm · 20°20 cm · 30°20 cm · 30°
ComputeNVIDIA Jetson Orin NXNVIDIA Jetson ThorNVIDIA Jetson Thor

The standard payload includes lidar, a depth camera, two cameras and an ultrasonic sensor. Sensing payloads such as a PTZ camera, thermal camera, gas sensor or leak detector can be added case by case.

See how it runs on your site.

Tell us about the site and we will scope the deployment with you.